

l0uai commited on
Commit ·
52f55f8
1
Parent(s): fcb9b70
Publish causal YellowCab benchmark and model card
Browse files- EVALUATION.md +94 -0
- README.md +228 -46
- benchmark.csv +7 -0
- benchmark.png +0 -0
- bundle_manifest.json +61 -21
- class_metrics.csv +31 -0
- classification_report.json +45 -0
- config.json +69 -32
- confusion_matrix.png +0 -0
- eval_predictions.csv +0 -0
- evaluation.json +344 -0
- model.safetensors +2 -2
- recompute_metrics.py +120 -0
- selective_metrics.csv +9 -0
- subset_metrics.csv +25 -0
EVALUATION.md
ADDED
|
@@ -0,0 +1,94 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
# YellowCab evaluation
|
| 2 |
+
|
| 3 |
+
## Question
|
| 4 |
+
|
| 5 |
+
Can three chronological road images combined with past-and-current telemetry
|
| 6 |
+
forecast a GPS-derived taxi maneuver approximately 20 seconds ahead better than
|
| 7 |
+
tested single-modality and rule-based baselines?
|
| 8 |
+
|
| 9 |
+
## Frozen evaluation contract
|
| 10 |
+
|
| 11 |
+
- Published model version: `v0.1-causal`
|
| 12 |
+
- Published Safetensors SHA-256:
|
| 13 |
+
`af1a98cd96bb68d642f7a0adeedfacac37b230917afc15f3c87230a99a15b8a2`
|
| 14 |
+
- Training manifest SHA-256:
|
| 15 |
+
`8b92ad563892776cc25148f39fec6bf207e1e442c618b58fb07af7e2b899364d`
|
| 16 |
+
- Split SHA-256:
|
| 17 |
+
`bfc5e960c8af32d0ea75a5e293bb95b3125111ace2cf8452eb42feb4bc2a1a5e`
|
| 18 |
+
- Seed: `20260726`
|
| 19 |
+
- Primary metric: macro F1
|
| 20 |
+
|
| 21 |
+
The split is forward in time by complete route. The earliest 26 routes are used
|
| 22 |
+
for training, the next five for validation, and the newest five for testing.
|
| 23 |
+
Frames never cross route boundaries between splits.
|
| 24 |
+
|
| 25 |
+
## Causal-input audit
|
| 26 |
+
|
| 27 |
+
The original dataset builder could use a future-bearing fallback when the
|
| 28 |
+
past-to-current displacement was too small to establish a reliable heading. The
|
| 29 |
+
causal manifest removes that fallback. When displacement is below four metres,
|
| 30 |
+
heading is represented as unknown using `(sin=0, cos=1)`.
|
| 31 |
+
|
| 32 |
+
The audit changed 5,974 of 74,680 rows:
|
| 33 |
+
|
| 34 |
+
- 4,552 training rows
|
| 35 |
+
- 819 validation rows
|
| 36 |
+
- 603 test rows
|
| 37 |
+
|
| 38 |
+
The released `v0.1-causal` checkpoint was trained on the corrected manifest.
|
| 39 |
+
Labels still use future trajectory by definition; model inputs do not.
|
| 40 |
+
|
| 41 |
+
## Metrics
|
| 42 |
+
|
| 43 |
+
Macro F1 is primary because the test set is imbalanced. Accuracy, balanced
|
| 44 |
+
accuracy, weighted F1, log loss, Brier score, and 15-bin expected calibration
|
| 45 |
+
error are secondary.
|
| 46 |
+
|
| 47 |
+
The macro-F1 confidence interval is computed with 500 bootstrap resamples of
|
| 48 |
+
complete test routes. This preserves within-route dependence instead of treating
|
| 49 |
+
8,594 sequential examples as independent observations.
|
| 50 |
+
|
| 51 |
+
## Reproduction from published predictions
|
| 52 |
+
|
| 53 |
+
The repository publishes labels, predictions, probabilities, and generic route
|
| 54 |
+
groups for every test example in `eval_predictions.csv`. It excludes images,
|
| 55 |
+
capture identifiers, timestamps, grid cells, and geographic data.
|
| 56 |
+
|
| 57 |
+
```bash
|
| 58 |
+
python -m pip install numpy pandas scikit-learn
|
| 59 |
+
python recompute_metrics.py
|
| 60 |
+
```
|
| 61 |
+
|
| 62 |
+
The script checks that probability rows sum to one and reproduces the core
|
| 63 |
+
point estimates and route-clustered macro-F1 interval.
|
| 64 |
+
|
| 65 |
+
## Selective prediction
|
| 66 |
+
|
| 67 |
+
`selective_metrics.csv` evaluates the confidence-based abstention rule. At the
|
| 68 |
+
default 0.45 threshold, the model retains 5,971 of 8,594 examples (69.5%
|
| 69 |
+
coverage). Accuracy among retained examples is 0.6583 and macro F1 is 0.4327.
|
| 70 |
+
|
| 71 |
+
Selective metrics describe only the accepted subset. They do not mean the
|
| 72 |
+
abstained examples disappear operationally; a real system must route them to a
|
| 73 |
+
fallback or human review process.
|
| 74 |
+
|
| 75 |
+
## Interpretation
|
| 76 |
+
|
| 77 |
+
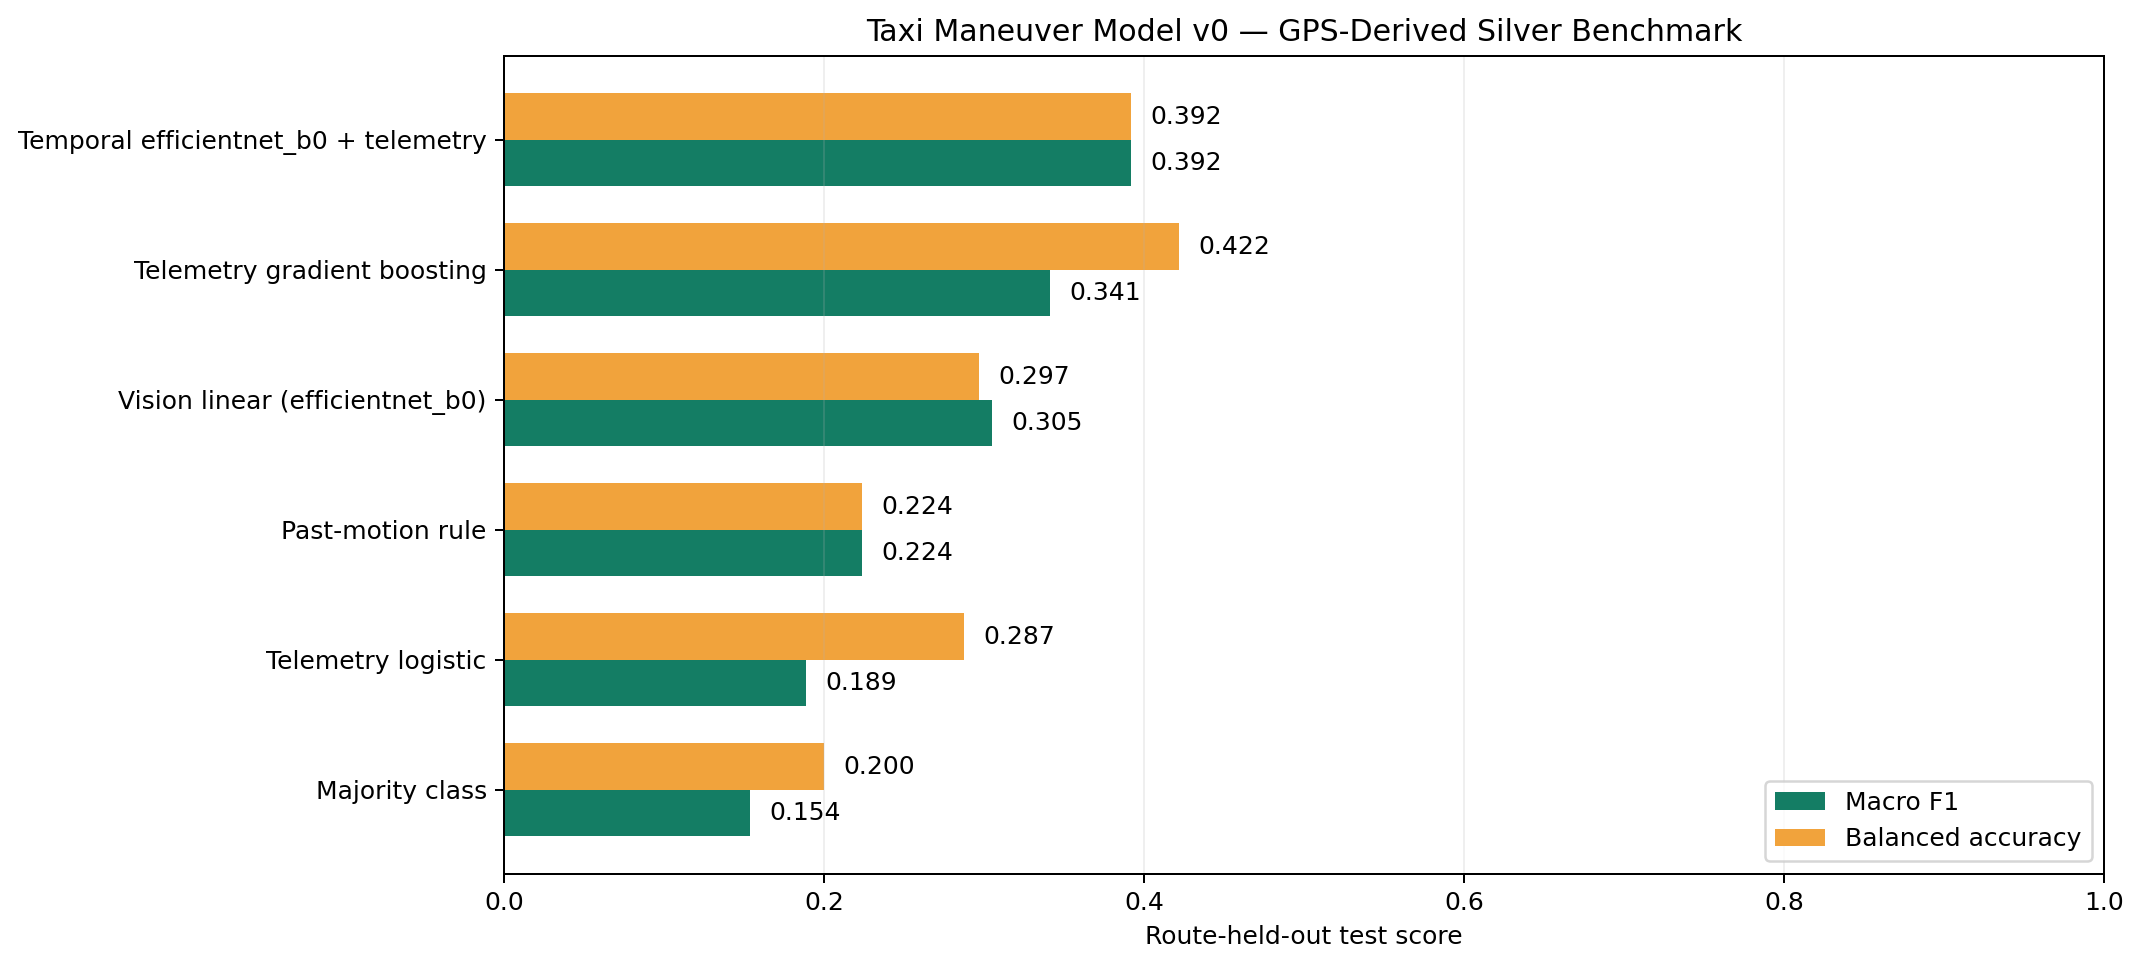
YellowCab has the highest macro F1 among the tested models. It does not win every
|
| 78 |
+
metric: telemetry gradient boosting has higher balanced accuracy, and a majority
|
| 79 |
+
classifier has higher raw accuracy because most examples are `continue`.
|
| 80 |
+
|
| 81 |
+
This supports use as a ranking, indexing, and research model. It does not support
|
| 82 |
+
claims of safe actuation, universal geographic generalization, or global
|
| 83 |
+
state-of-the-art status.
|
| 84 |
+
|
| 85 |
+
## Remaining evaluation work
|
| 86 |
+
|
| 87 |
+
A stronger future release should add:
|
| 88 |
+
|
| 89 |
+
- an independently human-labeled gold test set;
|
| 90 |
+
- a separate calibration split;
|
| 91 |
+
- evaluation across additional cities, camera mounts, weather, and daylight;
|
| 92 |
+
- selective-risk curves for the abstention threshold;
|
| 93 |
+
- an operational video-retrieval study at fixed event recall; and
|
| 94 |
+
- independent replication on a public, task-compatible benchmark.
|
README.md
CHANGED
|
@@ -4,18 +4,42 @@ license: apache-2.0
|
|
| 4 |
tags:
|
| 5 |
- driving
|
| 6 |
- multimodal
|
|
|
|
| 7 |
- time-series
|
|
|
|
| 8 |
- custom-handler
|
| 9 |
- research
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 10 |
---
|
| 11 |
|
| 12 |
# YellowCab
|
| 13 |
|
| 14 |
-
YellowCab is a multimodal
|
| 15 |
-
|
| 16 |
-
twelve telemetry
|
| 17 |
-
|
| 18 |
-
The output labels are:
|
| 19 |
|
| 20 |
- `continue`
|
| 21 |
- `slow`
|
|
@@ -23,31 +47,153 @@ The output labels are:
|
|
| 23 |
- `turn_left`
|
| 24 |
- `turn_right`
|
| 25 |
|
| 26 |
-
|
|
|
|
|
|
|
| 27 |
|
| 28 |
-
|
| 29 |
|
| 30 |
-
|
| 31 |
-
|
| 32 |
-
- a telemetry MLP over twelve normalized features; and
|
| 33 |
-
- a five-class fusion head with temperature scaling and optional abstention.
|
| 34 |
|
| 35 |
-
|
| 36 |
-
|
|
|
|
|
|
|
| 37 |
|
| 38 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
| 39 |
|
| 40 |
-
|
| 41 |
-
|
| 42 |
-
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 43 |
|
| 44 |
## Input
|
| 45 |
|
| 46 |
Requests require exactly three base64-encoded JPEG or PNG frames ordered oldest
|
| 47 |
-
to newest.
|
| 48 |
-
Optional frame timestamps must be strictly increasing.
|
| 49 |
|
| 50 |
-
All telemetry fields
|
| 51 |
|
| 52 |
`current_speed_mps`, `past_speed_mps`, `acceleration_mps2`,
|
| 53 |
`past_turn_degrees`, `past_yaw_rate_deg_s`, `heading_sin`, `heading_cos`,
|
|
@@ -77,29 +223,10 @@ All telemetry fields documented in `config.json` are required:
|
|
| 77 |
}
|
| 78 |
```
|
| 79 |
|
| 80 |
-
The custom `EndpointHandler`
|
| 81 |
-
|
| 82 |
-
|
| 83 |
-
image-classification `pipeline()` or widget.
|
| 84 |
-
|
| 85 |
-
## Evaluation
|
| 86 |
-
|
| 87 |
-
The release process included leakage-free held-out evaluation. Numeric results
|
| 88 |
-
are omitted until the corresponding report is published for this exact
|
| 89 |
-
checkpoint digest. Users should evaluate performance and calibration on their
|
| 90 |
-
own target domain.
|
| 91 |
-
|
| 92 |
-
## Intended use and limitations
|
| 93 |
-
|
| 94 |
-
YellowCab is intended for research, fleet analytics, and prototyping. Its labels
|
| 95 |
-
are GPS-derived maneuver proxies rather than human safety annotations.
|
| 96 |
-
Performance may vary with geography, weather, camera placement, traffic
|
| 97 |
-
conditions, and telemetry quality.
|
| 98 |
-
|
| 99 |
-
Telemetry supplied at inference time must be computed only from observations
|
| 100 |
-
available at or before the newest frame. YellowCab is not a safety-certified
|
| 101 |
-
system and should not be used as the sole input to steering, braking, throttle,
|
| 102 |
-
or other safety-critical decisions.
|
| 103 |
|
| 104 |
## Local use
|
| 105 |
|
|
@@ -116,9 +243,64 @@ predict = EndpointHandler(".")
|
|
| 116 |
result = predict(request_body)
|
| 117 |
```
|
| 118 |
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 119 |
## License
|
| 120 |
|
| 121 |
Unless otherwise noted, the model weights and original code, configuration, and
|
| 122 |
-
documentation
|
| 123 |
-
|
| 124 |
-
`THIRD_PARTY_NOTICES.md`.
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 4 |
tags:
|
| 5 |
- driving
|
| 6 |
- multimodal
|
| 7 |
+
- computer-vision
|
| 8 |
- time-series
|
| 9 |
+
- maneuver-forecasting
|
| 10 |
- custom-handler
|
| 11 |
- research
|
| 12 |
+
metrics:
|
| 13 |
+
- f1
|
| 14 |
+
- accuracy
|
| 15 |
+
model-index:
|
| 16 |
+
- name: YellowCab v0.1-causal
|
| 17 |
+
results:
|
| 18 |
+
- task:
|
| 19 |
+
type: image-classification
|
| 20 |
+
name: Multimodal maneuver forecasting
|
| 21 |
+
dataset:
|
| 22 |
+
name: YellowCab private forward-route holdout
|
| 23 |
+
type: private
|
| 24 |
+
split: test
|
| 25 |
+
metrics:
|
| 26 |
+
- type: f1
|
| 27 |
+
name: Macro F1
|
| 28 |
+
value: 0.3915542658
|
| 29 |
+
- type: accuracy
|
| 30 |
+
name: Balanced accuracy
|
| 31 |
+
value: 0.3915633404
|
| 32 |
+
- type: accuracy
|
| 33 |
+
name: Accuracy
|
| 34 |
+
value: 0.5755178031
|
| 35 |
---
|
| 36 |
|
| 37 |
# YellowCab
|
| 38 |
|
| 39 |
+
YellowCab is a compact multimodal model for forecasting a taxi's observed
|
| 40 |
+
maneuver approximately 20 seconds ahead. It combines three chronological road
|
| 41 |
+
images with twelve past-and-current telemetry signals and returns calibrated
|
| 42 |
+
probabilities for:
|
|
|
|
| 43 |
|
| 44 |
- `continue`
|
| 45 |
- `slow`
|
|
|
|
| 47 |
- `turn_left`
|
| 48 |
- `turn_right`
|
| 49 |
|
| 50 |
+
The model has **5.29 million parameters**. It is intended for fleet-video
|
| 51 |
+
indexing, maneuver analytics, multimodal research, and prototyping—not vehicle
|
| 52 |
+
control.
|
| 53 |
|
| 54 |
+
## What is technically useful about it?
|
| 55 |
|
| 56 |
+
YellowCab tests a practical hypothesis: recent visual context and vehicle motion
|
| 57 |
+
history are more useful together than either signal alone.
|
|
|
|
|
|
|
| 58 |
|
| 59 |
+
On the route-held-out silver benchmark, the causal temporal-fusion checkpoint
|
| 60 |
+
reaches **0.3916 macro F1**, compared with **0.3414** for the strongest tested
|
| 61 |
+
past-only telemetry baseline and **0.3050** for the tested current-frame
|
| 62 |
+
vision baseline. This supports uses such as:
|
| 63 |
|
| 64 |
+
- assigning likely maneuver tags to fleet footage;
|
| 65 |
+
- retrieving candidate stop and turn events for human review;
|
| 66 |
+
- prioritizing uncertain sequences for data collection or annotation;
|
| 67 |
+
- studying disagreement between visual and motion signals; and
|
| 68 |
+
- prototyping calibrated, abstaining multimodal classifiers.
|
| 69 |
|
| 70 |
+
These results do not establish a global rank. YellowCab uses a private,
|
| 71 |
+
task-specific benchmark and has not been evaluated under a directly comparable
|
| 72 |
+
public autonomous-driving leaderboard protocol.
|
| 73 |
+
|
| 74 |
+
## Architecture
|
| 75 |
+
|
| 76 |
+
- Frozen ImageNet-pretrained EfficientNet-B0 visual encoder
|
| 77 |
+
- Three frames at nominal offsets `t-20 s`, `t-10 s`, and `t`
|
| 78 |
+
- Layer normalization followed by a one-layer unidirectional GRU
|
| 79 |
+
- Telemetry MLP over twelve normalized causal features
|
| 80 |
+
- Fusion classifier over five maneuver classes
|
| 81 |
+
- Temperature scaling and optional confidence-based abstention
|
| 82 |
+
|
| 83 |
+
The repository contains the exact architecture, configuration, integrity-checked
|
| 84 |
+
Safetensors checkpoint, and custom Hugging Face endpoint handler.
|
| 85 |
+
|
| 86 |
+
## Evaluation
|
| 87 |
+
|
| 88 |
+
### Protocol
|
| 89 |
+
|
| 90 |
+
- **74,680** examples across **36** routes
|
| 91 |
+
- **55,711** training examples from 26 routes
|
| 92 |
+
- **10,375** validation examples from 5 routes
|
| 93 |
+
- **8,594** test examples from the newest 5 completely held-out routes
|
| 94 |
+
- Complete forward-in-time route separation
|
| 95 |
+
- No frame from a validation or test route enters training
|
| 96 |
+
- Model inputs use only information available at or before the newest frame
|
| 97 |
+
- Labels are GPS-derived maneuver proxies approximately 20 seconds ahead
|
| 98 |
+
- Primary metric: macro F1
|
| 99 |
+
- 95% confidence interval: 500 route-clustered bootstrap samples
|
| 100 |
+
|
| 101 |
+
### Headline results
|
| 102 |
+
|
| 103 |
+
| Metric | YellowCab |
|
| 104 |
+
| --- | ---: |
|
| 105 |
+
| Macro F1 | **0.3916** |
|
| 106 |
+
| Route-bootstrap 95% CI | **0.3476–0.4281** |
|
| 107 |
+
| Balanced accuracy | **0.3916** |
|
| 108 |
+
| Accuracy | **0.5755** |
|
| 109 |
+
| Weighted F1 | **0.5807** |
|
| 110 |
+
| Log loss | **1.0841** |
|
| 111 |
+
| Brier score | **0.5563** |
|
| 112 |
+
| ECE, 15 bins | **0.0118** |
|
| 113 |
+
|
| 114 |
+
Raw accuracy is not the primary metric because `continue` is the majority
|
| 115 |
+
class. A majority classifier reaches 0.6232 accuracy while scoring only 0.1536
|
| 116 |
+
macro F1.
|
| 117 |
+
|
| 118 |
+
### Baselines
|
| 119 |
+
|
| 120 |
+
| Model | Macro F1 | Balanced accuracy | Accuracy |
|
| 121 |
+
| --- | ---: | ---: | ---: |
|
| 122 |
+
| **YellowCab: temporal vision + telemetry** | **0.3916** | 0.3916 | 0.5755 |
|
| 123 |
+
| Telemetry gradient boosting | 0.3414 | **0.4217** | 0.4147 |
|
| 124 |
+
| Current-frame vision linear model | 0.3050 | 0.2968 | 0.5752 |
|
| 125 |
+
| Past-motion rule | 0.2235 | 0.2238 | 0.4550 |
|
| 126 |
+
| Telemetry logistic regression | 0.1887 | 0.2872 | 0.1963 |
|
| 127 |
+
| Majority class | 0.1536 | 0.2000 | **0.6232** |
|
| 128 |
+
|
| 129 |
+
YellowCab improves macro F1 over every tested baseline, but the gradient-boosted
|
| 130 |
+
telemetry baseline has higher balanced accuracy. We report both rather than
|
| 131 |
+
claiming uniform dominance.
|
| 132 |
+
|
| 133 |
+
### Per-class results
|
| 134 |
+
|
| 135 |
+
| Class | Precision | Recall | F1 | Support |
|
| 136 |
+
| --- | ---: | ---: | ---: | ---: |
|
| 137 |
+
| Continue | 0.7595 | 0.7394 | **0.7493** | 5,356 |
|
| 138 |
+
| Slow | 0.4031 | 0.3544 | **0.3772** | 951 |
|
| 139 |
+
| Stop | 0.3754 | 0.3423 | **0.3581** | 634 |
|
| 140 |
+
| Turn left | 0.2447 | 0.3157 | **0.2757** | 833 |
|
| 141 |
+
| Turn right | 0.1897 | 0.2061 | **0.1975** | 820 |
|
| 142 |
+
|
| 143 |
+
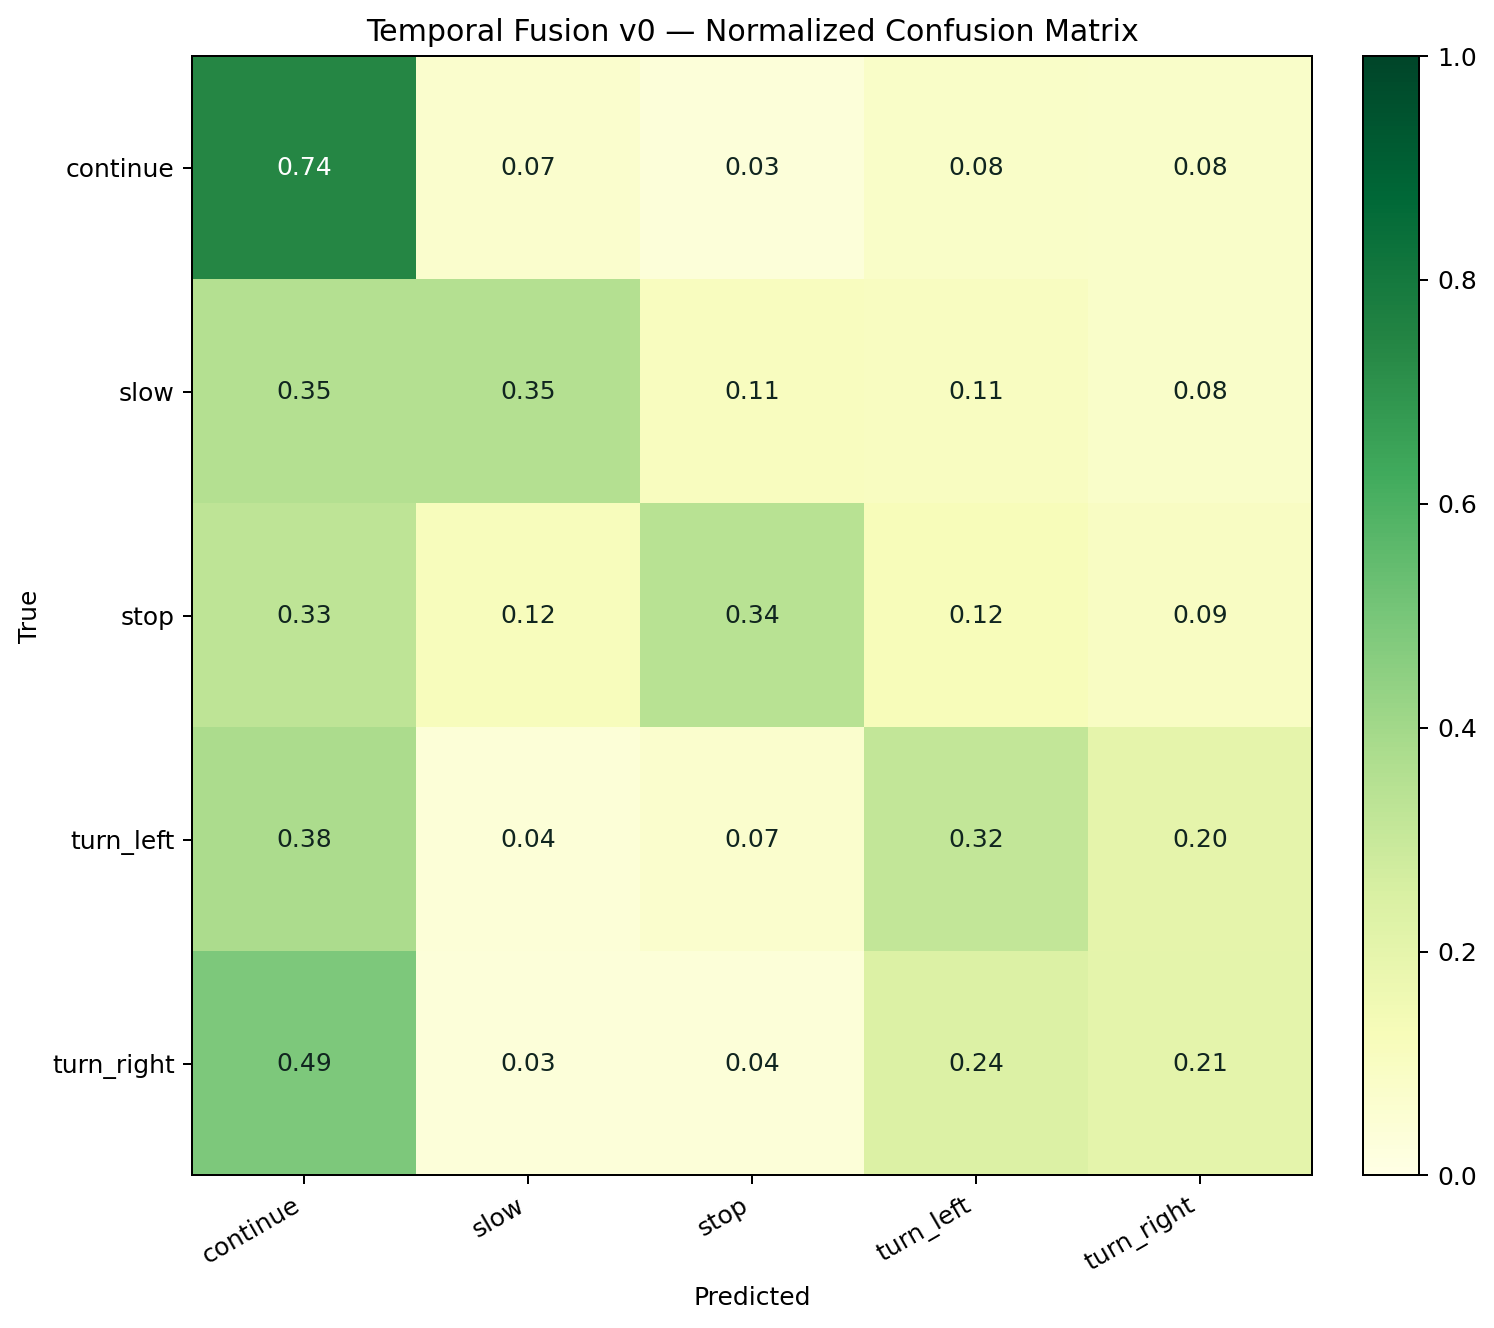
Turn performance is the clearest weakness. YellowCab should be used to produce
|
| 144 |
+
ranked candidates or analytics, not treated as a reliable maneuver oracle.
|
| 145 |
+
|
| 146 |
+
### Confidence-based abstention
|
| 147 |
+
|
| 148 |
+
The default confidence threshold is 0.45. On this held-out set it retains
|
| 149 |
+
**69.5%** of examples, with **0.6583 selective accuracy** and **0.4327 selective
|
| 150 |
+
macro F1** among retained examples. Raising the threshold trades coverage for
|
| 151 |
+
higher accuracy:
|
| 152 |
+
|
| 153 |
+
| Threshold | Coverage | Selective accuracy | Selective macro F1 |
|
| 154 |
+
| --- | ---: | ---: | ---: |
|
| 155 |
+
| 0.00 | 100.0% | 0.5755 | 0.3916 |
|
| 156 |
+
| 0.35 | 91.0% | 0.6007 | 0.4061 |
|
| 157 |
+
| **0.45** | **69.5%** | **0.6583** | **0.4327** |
|
| 158 |
+
| 0.55 | 47.2% | 0.7324 | 0.4702 |
|
| 159 |
+
| 0.65 | 30.2% | 0.8092 | 0.5275 |
|
| 160 |
+
|
| 161 |
+
This makes the model more useful for candidate retrieval and review queues, but
|
| 162 |
+
these thresholds must be recalibrated after domain shift. Full results are in
|
| 163 |
+
[`selective_metrics.csv`](selective_metrics.csv).
|
| 164 |
+
|
| 165 |
+

|
| 166 |
+
|
| 167 |
+

|
| 168 |
+
|
| 169 |
+
The complete checkpoint-specific report is in
|
| 170 |
+
[`evaluation.json`](evaluation.json). Recomputable, privacy-sanitized held-out
|
| 171 |
+
probabilities are in [`eval_predictions.csv`](eval_predictions.csv), and the
|
| 172 |
+
metric script is in [`recompute_metrics.py`](recompute_metrics.py). Additional
|
| 173 |
+
methodology and limitations are documented in
|
| 174 |
+
[`EVALUATION.md`](EVALUATION.md).
|
| 175 |
+
|
| 176 |
+
## Checkpoint identity
|
| 177 |
+
|
| 178 |
+
- Version: `v0.1-causal`
|
| 179 |
+
- Published checkpoint SHA-256:
|
| 180 |
+
`af1a98cd96bb68d642f7a0adeedfacac37b230917afc15f3c87230a99a15b8a2`
|
| 181 |
+
- Training manifest SHA-256:
|
| 182 |
+
`8b92ad563892776cc25148f39fec6bf207e1e442c618b58fb07af7e2b899364d`
|
| 183 |
+
- Split SHA-256:
|
| 184 |
+
`bfc5e960c8af32d0ea75a5e293bb95b3125111ace2cf8452eb42feb4bc2a1a5e`
|
| 185 |
+
- Training seed: `20260726`
|
| 186 |
+
|
| 187 |
+
The causal-manifest audit replaced unavailable current headings with the neutral
|
| 188 |
+
encoding `(sin=0, cos=1)` rather than deriving them from future motion. The
|
| 189 |
+
published checkpoint was trained and evaluated on that corrected manifest.
|
| 190 |
|
| 191 |
## Input
|
| 192 |
|
| 193 |
Requests require exactly three base64-encoded JPEG or PNG frames ordered oldest
|
| 194 |
+
to newest. Optional frame timestamps must be strictly increasing.
|
|
|
|
| 195 |
|
| 196 |
+
All telemetry fields are required:
|
| 197 |
|
| 198 |
`current_speed_mps`, `past_speed_mps`, `acceleration_mps2`,
|
| 199 |
`past_turn_degrees`, `past_yaw_rate_deg_s`, `heading_sin`, `heading_cos`,
|
|
|
|
| 223 |
}
|
| 224 |
```
|
| 225 |
|
| 226 |
+
The custom `EndpointHandler` validates the request and returns the predicted
|
| 227 |
+
label, ordered class probabilities, confidence, and abstention state. This
|
| 228 |
+
custom multimodal architecture is not compatible with the standard
|
| 229 |
+
image-classification `pipeline()` or Hub widget.
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 230 |
|
| 231 |
## Local use
|
| 232 |
|
|
|
|
| 243 |
result = predict(request_body)
|
| 244 |
```
|
| 245 |
|
| 246 |
+
## Training data and privacy
|
| 247 |
+
|
| 248 |
+
The model was trained on privacy-redacted imagery collected from the operator's
|
| 249 |
+
taxi fleet under contributor agreements authorizing model training. No source
|
| 250 |
+
imagery, exact GPS records, route manifests, or personal identifiers are
|
| 251 |
+
distributed in this repository.
|
| 252 |
+
|
| 253 |
+
The published evaluation predictions use sequential example identifiers and
|
| 254 |
+
generic held-out route groups. Capture identifiers, timestamps, grid cells, and
|
| 255 |
+
locations have been removed.
|
| 256 |
+
|
| 257 |
+
## Intended uses
|
| 258 |
+
|
| 259 |
+
- Offline fleet-video indexing and search
|
| 260 |
+
- Maneuver analytics and aggregate research
|
| 261 |
+
- Candidate-event retrieval followed by human review
|
| 262 |
+
- Multimodal classification and calibration research
|
| 263 |
+
- Prototyping and collection-planning experiments
|
| 264 |
+
|
| 265 |
+
## Out-of-scope uses
|
| 266 |
+
|
| 267 |
+
Do not use YellowCab:
|
| 268 |
+
|
| 269 |
+
- as the sole input to steering, braking, throttle, or dispatch decisions;
|
| 270 |
+
- as a safety-certified driver-assistance component;
|
| 271 |
+
- to identify drivers, passengers, pedestrians, or locations;
|
| 272 |
+
- to infer intent, fault, liability, or legal compliance; or
|
| 273 |
+
- outside a target domain without measuring performance and calibration again.
|
| 274 |
+
|
| 275 |
+
## Limitations
|
| 276 |
+
|
| 277 |
+
- Ground truth is GPS-derived silver labeling, not independent human annotation.
|
| 278 |
+
- The evaluation covers five held-out routes from one operating domain.
|
| 279 |
+
- Geography, weather, camera placement, traffic, and telemetry quality can shift
|
| 280 |
+
performance.
|
| 281 |
+
- Rare classes are substantially weaker than `continue`.
|
| 282 |
+
- Temperature scaling used the validation split rather than a separate
|
| 283 |
+
calibration split.
|
| 284 |
+
- No membership-inference, model-inversion, or differential-privacy assessment
|
| 285 |
+
has been completed.
|
| 286 |
+
- Benchmark results are author-reported and have not been independently
|
| 287 |
+
replicated on a public dataset.
|
| 288 |
+
|
| 289 |
## License
|
| 290 |
|
| 291 |
Unless otherwise noted, the model weights and original code, configuration, and
|
| 292 |
+
documentation are licensed under the Apache License 2.0. Third-party components
|
| 293 |
+
remain subject to their respective terms; see
|
| 294 |
+
[`THIRD_PARTY_NOTICES.md`](THIRD_PARTY_NOTICES.md).
|
| 295 |
+
|
| 296 |
+
## Citation
|
| 297 |
+
|
| 298 |
+
```bibtex
|
| 299 |
+
@software{yellowcab_v0_1_causal_2026,
|
| 300 |
+
author = {{The General Data Corporation}},
|
| 301 |
+
title = {YellowCab: Multimodal Taxi Maneuver Forecasting},
|
| 302 |
+
year = {2026},
|
| 303 |
+
version = {v0.1-causal},
|
| 304 |
+
url = {https://huggingface.co/generaldata/YellowCab}
|
| 305 |
+
}
|
| 306 |
+
```
|
benchmark.csv
ADDED
|
@@ -0,0 +1,7 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
model,samples,accuracy,balanced_accuracy,macro_f1,weighted_f1,log_loss,brier_score,ece_15_bin,p95_latency_ms,continue_recall,continue_f1,slow_recall,slow_f1,stop_recall,stop_f1,turn_left_recall,turn_left_f1,turn_right_recall,turn_right_f1,macro_f1_route_ci_low,macro_f1_route_ci_high
|
| 2 |
+
Temporal efficientnet_b0 + telemetry,8594,0.5755178031184547,0.39156334041323,0.3915542657655546,0.5807008272180106,1.0841176199931875,0.5563128377237149,0.011817411647322817,95.37229499110252,0.7393577296489918,0.7492904446546831,0.35436382754994744,0.37716843872411865,0.3422712933753943,0.3580858085808581,0.3157262905162065,0.27568134171907754,0.20609756097560974,0.19754529514903565,0.34762239048615595,0.42805096076291543
|
| 3 |
+
Telemetry gradient boosting,8594,0.4147079357691413,0.42166330996553986,0.341392924380058,0.45303568638063824,1.2490630281069546,0.6566714449096165,0.12167008852186818,,0.4051530993278566,0.5513911828230212,0.6466876971608833,0.3416666666666667,0.4889589905362776,0.29865125240847784,0.2797118847539016,0.2583148558758315,0.28780487804878047,0.25694066412629285,0.3149153283503967,0.34939970154465316
|
| 4 |
+
Vision linear (efficientnet_b0),8594,0.5751687223644403,0.2967510353079744,0.30503460507355407,0.5344562546214928,10.24602122531317,0.8349054717132016,0.40913361870747145,,0.8269230769230769,0.7406354515050168,0.15562565720294427,0.21480406386066764,0.25236593059936907,0.25559105431309903,0.15006002400960383,0.18102824040550325,0.09878048780487805,0.13311421528348397,0.26780560056303193,0.32731434371479995
|
| 5 |
+
Past-motion rule,8594,0.4549685827321387,0.22377382659168304,0.22352977859537337,0.45325423166470347,2.058490921490782,0.966304980218757,0.44503141726786155,,0.6562733383121733,0.6534064504136072,0.10199789695057834,0.09627791563275434,0.0,0.0,0.17767106842737096,0.17928528164748636,0.18292682926829268,0.18867924528301888,0.18734638205859894,0.23451957590710315
|
| 6 |
+
Telemetry logistic,8594,0.19629974400744707,0.2871892331606019,0.1886698746182765,0.18614071585068767,1.5832758165931655,0.8215841116420504,0.1432688177654283,,0.109596713965646,0.18162128712871287,0.601472134595163,0.25060240963855424,0.37066246056782337,0.17609591607343575,0.19567827130852342,0.17212249208025343,0.15853658536585366,0.16290726817042606,0.1839562547318565,0.20443593471582872
|
| 7 |
+
Majority class,8594,0.6232255061670933,0.2,0.15357706093189966,0.4785657076746885,1.1837257781136636,0.5768401032344809,0.03274965759140802,,1.0,0.7678853046594982,0.0,0.0,0.0,0.0,0.0,0.0,0.0,0.0,0.14609150326797388,0.1554760284937855
|
benchmark.png
ADDED
|
bundle_manifest.json
CHANGED
|
@@ -1,53 +1,93 @@
|
|
| 1 |
{
|
| 2 |
-
"schema": "
|
| 3 |
-
"model_id": "generaldata/YellowCab",
|
| 4 |
-
"model_version": "v0",
|
| 5 |
-
"license": "Apache-2.0",
|
| 6 |
-
"note": "bundle_manifest.json intentionally does not hash itself",
|
| 7 |
"files": {
|
| 8 |
".gitattributes": {
|
| 9 |
"bytes": 69,
|
| 10 |
"sha256": "14281383ff036613975d5f219e22a1102041eb14de55c3f34db8223bb0784145"
|
| 11 |
},
|
| 12 |
-
"
|
| 13 |
-
"bytes":
|
| 14 |
-
"sha256": "
|
| 15 |
},
|
| 16 |
-
"
|
| 17 |
-
"bytes":
|
| 18 |
-
"sha256": "
|
| 19 |
},
|
| 20 |
-
"
|
| 21 |
-
"bytes":
|
| 22 |
-
"sha256": "
|
| 23 |
},
|
| 24 |
-
"
|
| 25 |
-
"bytes":
|
| 26 |
-
"sha256": "
|
| 27 |
},
|
| 28 |
"config.json": {
|
| 29 |
-
"bytes":
|
| 30 |
-
"sha256": "
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 31 |
},
|
| 32 |
"handler.py": {
|
| 33 |
"bytes": 17681,
|
| 34 |
"sha256": "a8a3c804e71e4864ac26cae394d9f1e32af86d38ae939226066e1c9767ac2eaa"
|
| 35 |
},
|
|
|
|
|
|
|
|
|
|
|
|
|
| 36 |
"model.py": {
|
| 37 |
"bytes": 8419,
|
| 38 |
"sha256": "48cf1aafb242a497be2ec9ad7abd6211608cf04e98c9fae20d5878ba8a09bc52"
|
| 39 |
},
|
| 40 |
"model.safetensors": {
|
| 41 |
-
"bytes":
|
| 42 |
-
"sha256": "
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 43 |
},
|
| 44 |
"requirements.txt": {
|
| 45 |
"bytes": 80,
|
| 46 |
"sha256": "92f03418ab85f5cb1239971fb4515cf1d2acc9aed7013d0aca74b17daa3f97ef"
|
| 47 |
},
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 48 |
"THIRD_PARTY_LICENSES/torchvision-BSD-3-Clause.txt": {
|
| 49 |
"bytes": 1516,
|
| 50 |
"sha256": "2b63e4f6569e0e58260881a1f7ea8b1d9802859ab3cb4b32a45cba246245c8da"
|
|
|
|
|
|
|
|
|
|
|
|
|
| 51 |
}
|
| 52 |
}
|
| 53 |
}
|
|
|
|
| 1 |
{
|
| 2 |
+
"schema": "gdc_yellowcab_public_bundle_v2",
|
|
|
|
|
|
|
|
|
|
|
|
|
| 3 |
"files": {
|
| 4 |
".gitattributes": {
|
| 5 |
"bytes": 69,
|
| 6 |
"sha256": "14281383ff036613975d5f219e22a1102041eb14de55c3f34db8223bb0784145"
|
| 7 |
},
|
| 8 |
+
"benchmark.csv": {
|
| 9 |
+
"bytes": 2524,
|
| 10 |
+
"sha256": "177d024f407c9e064b63eff4b0e594deb0ae6b861ce342c63e9bfc2458ff83e0"
|
| 11 |
},
|
| 12 |
+
"benchmark.png": {
|
| 13 |
+
"bytes": 98848,
|
| 14 |
+
"sha256": "31e491792a60685e15a373cb1919bb732aaa675ca0bce5b5f38270c32d6c6a9a"
|
| 15 |
},
|
| 16 |
+
"class_metrics.csv": {
|
| 17 |
+
"bytes": 2679,
|
| 18 |
+
"sha256": "bf35d02ca99e765be4926d95d6f197488569bf902c944eca97d2f954a5c87003"
|
| 19 |
},
|
| 20 |
+
"classification_report.json": {
|
| 21 |
+
"bytes": 1128,
|
| 22 |
+
"sha256": "3c10ff529643649eb2b72f79244f6370c2ff9fe0c34e27b0600fe951047a7969"
|
| 23 |
},
|
| 24 |
"config.json": {
|
| 25 |
+
"bytes": 10944,
|
| 26 |
+
"sha256": "2a221f468f350360ed704f6552400312f67057fdc5610e795162a711a5636b9b"
|
| 27 |
+
},
|
| 28 |
+
"confusion_matrix.png": {
|
| 29 |
+
"bytes": 96286,
|
| 30 |
+
"sha256": "31fa8526560d76bc9600a40a6e48b2d6ef929934c54d8371e855de93431a5482"
|
| 31 |
+
},
|
| 32 |
+
"eval_predictions.csv": {
|
| 33 |
+
"bytes": 1156310,
|
| 34 |
+
"sha256": "d76846904ed54093d53a77610f040e2e9a6476cd2c06bd13edbf121ca9875dff"
|
| 35 |
+
},
|
| 36 |
+
"evaluation.json": {
|
| 37 |
+
"bytes": 12235,
|
| 38 |
+
"sha256": "e8890addffda4ec495a219f7439bb4d9ece5934f536e35d7f340830b475cbe21"
|
| 39 |
+
},
|
| 40 |
+
"EVALUATION.md": {
|
| 41 |
+
"bytes": 3606,
|
| 42 |
+
"sha256": "31d29ab99ac4761662a1bd4646e4c317deedb60c79577b844472485085f6a710"
|
| 43 |
},
|
| 44 |
"handler.py": {
|
| 45 |
"bytes": 17681,
|
| 46 |
"sha256": "a8a3c804e71e4864ac26cae394d9f1e32af86d38ae939226066e1c9767ac2eaa"
|
| 47 |
},
|
| 48 |
+
"LICENSE": {
|
| 49 |
+
"bytes": 11357,
|
| 50 |
+
"sha256": "c71d239df91726fc519c6eb72d318ec65820627232b2f796219e87dcf35d0ab4"
|
| 51 |
+
},
|
| 52 |
"model.py": {
|
| 53 |
"bytes": 8419,
|
| 54 |
"sha256": "48cf1aafb242a497be2ec9ad7abd6211608cf04e98c9fae20d5878ba8a09bc52"
|
| 55 |
},
|
| 56 |
"model.safetensors": {
|
| 57 |
+
"bytes": 21384748,
|
| 58 |
+
"sha256": "af1a98cd96bb68d642f7a0adeedfacac37b230917afc15f3c87230a99a15b8a2"
|
| 59 |
+
},
|
| 60 |
+
"NOTICE": {
|
| 61 |
+
"bytes": 622,
|
| 62 |
+
"sha256": "1983f5396c5d59083231fdf3516feacc267b13bbe8090b31804260fde5c39c72"
|
| 63 |
+
},
|
| 64 |
+
"README.md": {
|
| 65 |
+
"bytes": 10588,
|
| 66 |
+
"sha256": "6012ebee2b3d34d3117aaac5e2c1143e07f583b9c61fe6bc8cf1483c820cd8a4"
|
| 67 |
+
},
|
| 68 |
+
"recompute_metrics.py": {
|
| 69 |
+
"bytes": 3963,
|
| 70 |
+
"sha256": "dd2f8aeda429cfecb5204e6b2ed563a3d269500b0112ab6e7558a576f50dac5f"
|
| 71 |
},
|
| 72 |
"requirements.txt": {
|
| 73 |
"bytes": 80,
|
| 74 |
"sha256": "92f03418ab85f5cb1239971fb4515cf1d2acc9aed7013d0aca74b17daa3f97ef"
|
| 75 |
},
|
| 76 |
+
"selective_metrics.csv": {
|
| 77 |
+
"bytes": 614,
|
| 78 |
+
"sha256": "e39afd4baf6104eced16f0658f19b3abb7f5278f29fe7cc641a544910eb28606"
|
| 79 |
+
},
|
| 80 |
+
"subset_metrics.csv": {
|
| 81 |
+
"bytes": 2430,
|
| 82 |
+
"sha256": "7de2bb82af604e2d5acc2276c345b7d01467b596f2196511394d2f3c60c569e4"
|
| 83 |
+
},
|
| 84 |
"THIRD_PARTY_LICENSES/torchvision-BSD-3-Clause.txt": {
|
| 85 |
"bytes": 1516,
|
| 86 |
"sha256": "2b63e4f6569e0e58260881a1f7ea8b1d9802859ab3cb4b32a45cba246245c8da"
|
| 87 |
+
},
|
| 88 |
+
"THIRD_PARTY_NOTICES.md": {
|
| 89 |
+
"bytes": 1454,
|
| 90 |
+
"sha256": "38f7bb94a0824965ac7cff7cc2f4378a0a44cbe08aad02b97468d86243b2da1d"
|
| 91 |
}
|
| 92 |
}
|
| 93 |
}
|
class_metrics.csv
ADDED
|
@@ -0,0 +1,31 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
model,class,precision,recall,f1,support
|
| 2 |
+
Majority class,continue,0.6232255061670933,1.0,0.7678853046594982,5356
|
| 3 |
+
Majority class,slow,0.0,0.0,0.0,951
|
| 4 |
+
Majority class,stop,0.0,0.0,0.0,634
|
| 5 |
+
Majority class,turn_left,0.0,0.0,0.0,833
|
| 6 |
+
Majority class,turn_right,0.0,0.0,0.0,820
|
| 7 |
+
Past-motion rule,continue,0.6505645012030353,0.6562733383121733,0.6534064504136072,5356
|
| 8 |
+
Past-motion rule,slow,0.09116541353383459,0.10199789695057834,0.09627791563275434,951
|
| 9 |
+
Past-motion rule,stop,0.0,0.0,0.0,634
|
| 10 |
+
Past-motion rule,turn_left,0.18092909535452323,0.17767106842737096,0.17928528164748636,833
|
| 11 |
+
Past-motion rule,turn_right,0.19480519480519481,0.18292682926829268,0.18867924528301888,820
|
| 12 |
+
Telemetry logistic,continue,0.529783393501805,0.109596713965646,0.18162128712871287,5356
|
| 13 |
+
Telemetry logistic,slow,0.15827338129496402,0.601472134595163,0.25060240963855424,951
|
| 14 |
+
Telemetry logistic,stop,0.11547911547911548,0.37066246056782337,0.17609591607343575,634
|
| 15 |
+
Telemetry logistic,turn_left,0.1536286522148916,0.19567827130852342,0.17212249208025343,833
|
| 16 |
+
Telemetry logistic,turn_right,0.16752577319587628,0.15853658536585366,0.16290726817042606,820
|
| 17 |
+
Telemetry gradient boosting,continue,0.8628230616302187,0.4051530993278566,0.5513911828230212,5356
|
| 18 |
+
Telemetry gradient boosting,slow,0.232163080407701,0.6466876971608833,0.3416666666666667,951
|
| 19 |
+
Telemetry gradient boosting,stop,0.21497919556171982,0.4889589905362776,0.29865125240847784,634
|
| 20 |
+
Telemetry gradient boosting,turn_left,0.2399588053553038,0.2797118847539016,0.2583148558758315,833
|
| 21 |
+
Telemetry gradient boosting,turn_right,0.232055063913471,0.28780487804878047,0.25694066412629285,820
|
| 22 |
+
Vision linear (efficientnet_b0),continue,0.6706541490006057,0.8269230769230769,0.7406354515050168,5356
|
| 23 |
+
Vision linear (efficientnet_b0),slow,0.34660421545667447,0.15562565720294427,0.21480406386066764,951
|
| 24 |
+
Vision linear (efficientnet_b0),stop,0.2588996763754045,0.25236593059936907,0.25559105431309903,634
|
| 25 |
+
Vision linear (efficientnet_b0),turn_left,0.2281021897810219,0.15006002400960383,0.18102824040550325,833
|
| 26 |
+
Vision linear (efficientnet_b0),turn_right,0.2040302267002519,0.09878048780487805,0.13311421528348397,820
|
| 27 |
+
Temporal efficientnet_b0 + telemetry,continue,0.759493670886076,0.7393577296489918,0.7492904446546831,5356
|
| 28 |
+
Temporal efficientnet_b0 + telemetry,slow,0.40311004784689,0.35436382754994744,0.37716843872411865,951
|
| 29 |
+
Temporal efficientnet_b0 + telemetry,stop,0.3754325259515571,0.3422712933753943,0.3580858085808581,634
|
| 30 |
+
Temporal efficientnet_b0 + telemetry,turn_left,0.24465116279069768,0.3157262905162065,0.27568134171907754,833
|
| 31 |
+
Temporal efficientnet_b0 + telemetry,turn_right,0.18967452300785634,0.20609756097560974,0.19754529514903565,820
|
classification_report.json
ADDED
|
@@ -0,0 +1,45 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
{
|
| 2 |
+
"continue": {
|
| 3 |
+
"precision": 0.759493670886076,
|
| 4 |
+
"recall": 0.7393577296489918,
|
| 5 |
+
"f1-score": 0.7492904446546831,
|
| 6 |
+
"support": 5356.0
|
| 7 |
+
},
|
| 8 |
+
"slow": {
|
| 9 |
+
"precision": 0.40311004784689,
|
| 10 |
+
"recall": 0.35436382754994744,
|
| 11 |
+
"f1-score": 0.37716843872411865,
|
| 12 |
+
"support": 951.0
|
| 13 |
+
},
|
| 14 |
+
"stop": {
|
| 15 |
+
"precision": 0.3754325259515571,
|
| 16 |
+
"recall": 0.3422712933753943,
|
| 17 |
+
"f1-score": 0.3580858085808581,
|
| 18 |
+
"support": 634.0
|
| 19 |
+
},
|
| 20 |
+
"turn_left": {
|
| 21 |
+
"precision": 0.24465116279069768,
|
| 22 |
+
"recall": 0.3157262905162065,
|
| 23 |
+
"f1-score": 0.27568134171907754,
|
| 24 |
+
"support": 833.0
|
| 25 |
+
},
|
| 26 |
+
"turn_right": {
|
| 27 |
+
"precision": 0.18967452300785634,
|
| 28 |
+
"recall": 0.20609756097560974,
|
| 29 |
+
"f1-score": 0.19754529514903565,
|
| 30 |
+
"support": 820.0
|
| 31 |
+
},
|
| 32 |
+
"accuracy": 0.5755178031184547,
|
| 33 |
+
"macro avg": {
|
| 34 |
+
"precision": 0.3944723860966154,
|
| 35 |
+
"recall": 0.39156334041323,
|
| 36 |
+
"f1-score": 0.3915542657655546,
|
| 37 |
+
"support": 8594.0
|
| 38 |
+
},
|
| 39 |
+
"weighted avg": {
|
| 40 |
+
"precision": 0.5874514202574582,
|
| 41 |
+
"recall": 0.5755178031184547,
|
| 42 |
+
"f1-score": 0.5807008272180106,
|
| 43 |
+
"support": 8594.0
|
| 44 |
+
}
|
| 45 |
+
}
|
config.json
CHANGED
|
@@ -2,7 +2,7 @@
|
|
| 2 |
"schema": "gdc_taxi_maneuver_release_config_v1",
|
| 3 |
"model_id": "generaldata/YellowCab",
|
| 4 |
"model_name": "YellowCab",
|
| 5 |
-
"model_version": "v0",
|
| 6 |
"task": "predict a GPS-derived maneuver proxy approximately 20 seconds ahead",
|
| 7 |
"release_status": "public_research_release",
|
| 8 |
"actuation_allowed": false,
|
|
@@ -212,34 +212,34 @@
|
|
| 212 |
"source_example_count": 55711,
|
| 213 |
"standard_deviation": "population_ddof_0",
|
| 214 |
"missing_value_imputation_used": false,
|
| 215 |
-
"arithmetic": "parse as float64, subtract
|
| 216 |
"mean": [
|
| 217 |
-
5.
|
| 218 |
-
5.
|
| 219 |
-
0.
|
| 220 |
-
-0.
|
| 221 |
-
-0.
|
| 222 |
-
-0.
|
| 223 |
-
0.
|
| 224 |
-
4.
|
| 225 |
-
-0.
|
| 226 |
-
0.
|
| 227 |
-
0.
|
| 228 |
-
-0.
|
| 229 |
],
|
| 230 |
"std": [
|
| 231 |
-
5.
|
| 232 |
-
5.
|
| 233 |
-
0.
|
| 234 |
-
34.
|
| 235 |
-
1.
|
| 236 |
-
0.
|
| 237 |
-
0.
|
| 238 |
-
1.
|
| 239 |
-
0.
|
| 240 |
-
0.
|
| 241 |
-
0.
|
| 242 |
-
0.
|
| 243 |
]
|
| 244 |
}
|
| 245 |
},
|
|
@@ -261,8 +261,8 @@
|
|
| 261 |
},
|
| 262 |
"calibration": {
|
| 263 |
"method": "temperature_scaling",
|
| 264 |
-
"temperature":
|
| 265 |
-
"fit_split": "
|
| 266 |
"independent_calibration_split": false
|
| 267 |
},
|
| 268 |
"abstention": {
|
|
@@ -272,18 +272,55 @@
|
|
| 272 |
},
|
| 273 |
"checkpoint": {
|
| 274 |
"file": "model.safetensors",
|
| 275 |
-
"sha256": "
|
| 276 |
-
"bytes":
|
| 277 |
"parameter_count": 5294233,
|
| 278 |
"state_tensor_count": 376,
|
| 279 |
"state_numel": 5336298,
|
| 280 |
"state_dtypes": {
|
| 281 |
"torch.float32": 327,
|
| 282 |
"torch.int64": 49
|
| 283 |
-
}
|
|
|
|
| 284 |
},
|
| 285 |
"warnings": [
|
| 286 |
"research model; not a safety-certified vehicle-control system",
|
| 287 |
"validate performance and calibration for the intended domain before use"
|
| 288 |
-
]
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 289 |
}
|
|
|
|
| 2 |
"schema": "gdc_taxi_maneuver_release_config_v1",
|
| 3 |
"model_id": "generaldata/YellowCab",
|
| 4 |
"model_name": "YellowCab",
|
| 5 |
+
"model_version": "v0.1-causal",
|
| 6 |
"task": "predict a GPS-derived maneuver proxy approximately 20 seconds ahead",
|
| 7 |
"release_status": "public_research_release",
|
| 8 |
"actuation_allowed": false,
|
|
|
|
| 212 |
"source_example_count": 55711,
|
| 213 |
"standard_deviation": "population_ddof_0",
|
| 214 |
"missing_value_imputation_used": false,
|
| 215 |
+
"arithmetic": "parse as float64, subtract float32 training mean, divide by float32 training standard deviation, then cast to float32",
|
| 216 |
"mean": [
|
| 217 |
+
5.1570844650268555,
|
| 218 |
+
5.055907726287842,
|
| 219 |
+
0.005347144324332476,
|
| 220 |
+
-0.7335137724876404,
|
| 221 |
+
-0.03728550672531128,
|
| 222 |
+
-0.01271896529942751,
|
| 223 |
+
0.08169970661401749,
|
| 224 |
+
4.2314910888671875,
|
| 225 |
+
-0.2427283227443695,
|
| 226 |
+
0.6515114307403564,
|
| 227 |
+
0.08530019223690033,
|
| 228 |
+
-0.07634009420871735
|
| 229 |
],
|
| 230 |
"std": [
|
| 231 |
+
5.041778087615967,
|
| 232 |
+
5.1640753746032715,
|
| 233 |
+
0.16992051899433136,
|
| 234 |
+
34.073089599609375,
|
| 235 |
+
1.736711025238037,
|
| 236 |
+
0.6867451071739197,
|
| 237 |
+
0.7221804261207581,
|
| 238 |
+
1.9923152923583984,
|
| 239 |
+
0.6107164621353149,
|
| 240 |
+
0.3790002763271332,
|
| 241 |
+
0.6974503397941589,
|
| 242 |
+
0.7074313163757324
|
| 243 |
]
|
| 244 |
}
|
| 245 |
},
|
|
|
|
| 261 |
},
|
| 262 |
"calibration": {
|
| 263 |
"method": "temperature_scaling",
|
| 264 |
+
"temperature": 1.106177568435669,
|
| 265 |
+
"fit_split": "validation_after_restoring_best_epoch_4",
|
| 266 |
"independent_calibration_split": false
|
| 267 |
},
|
| 268 |
"abstention": {
|
|
|
|
| 272 |
},
|
| 273 |
"checkpoint": {
|
| 274 |
"file": "model.safetensors",
|
| 275 |
+
"sha256": "af1a98cd96bb68d642f7a0adeedfacac37b230917afc15f3c87230a99a15b8a2",
|
| 276 |
+
"bytes": 21384748,
|
| 277 |
"parameter_count": 5294233,
|
| 278 |
"state_tensor_count": 376,
|
| 279 |
"state_numel": 5336298,
|
| 280 |
"state_dtypes": {
|
| 281 |
"torch.float32": 327,
|
| 282 |
"torch.int64": 49
|
| 283 |
+
},
|
| 284 |
+
"source_checkpoint_sha256": "0cb9c71d5be8f7671029e459c24179863ae2abff3ccfec1b5837c169d7d6c703"
|
| 285 |
},
|
| 286 |
"warnings": [
|
| 287 |
"research model; not a safety-certified vehicle-control system",
|
| 288 |
"validate performance and calibration for the intended domain before use"
|
| 289 |
+
],
|
| 290 |
+
"training": {
|
| 291 |
+
"manifest_sha256": "8b92ad563892776cc25148f39fec6bf207e1e442c618b58fb07af7e2b899364d",
|
| 292 |
+
"split_sha256": "bfc5e960c8af32d0ea75a5e293bb95b3125111ace2cf8452eb42feb4bc2a1a5e",
|
| 293 |
+
"samples": 74680,
|
| 294 |
+
"routes": 36,
|
| 295 |
+
"split_samples": {
|
| 296 |
+
"train": 55711,
|
| 297 |
+
"validation": 10375,
|
| 298 |
+
"test": 8594
|
| 299 |
+
},
|
| 300 |
+
"split_routes": {
|
| 301 |
+
"train": 26,
|
| 302 |
+
"validation": 5,
|
| 303 |
+
"test": 5
|
| 304 |
+
},
|
| 305 |
+
"seed": 20260726,
|
| 306 |
+
"epochs_completed": 8,
|
| 307 |
+
"best_validation_macro_f1": 0.37644976936491265,
|
| 308 |
+
"causal_input_policy": "When past-to-current displacement is below 4 m, encode unknown current heading as sin=0 and cos=1. No future bearing is used.",
|
| 309 |
+
"future_derived_model_inputs": 0
|
| 310 |
+
},
|
| 311 |
+
"evaluation": {
|
| 312 |
+
"artifact": "evaluation.json",
|
| 313 |
+
"checkpoint_specific": true,
|
| 314 |
+
"primary_metric": "macro_f1",
|
| 315 |
+
"test_samples": 8594,
|
| 316 |
+
"test_routes": 5,
|
| 317 |
+
"macro_f1": 0.3915542657655546,
|
| 318 |
+
"macro_f1_route_ci_95": [
|
| 319 |
+
0.34762239048615595,
|
| 320 |
+
0.42805096076291543
|
| 321 |
+
],
|
| 322 |
+
"balanced_accuracy": 0.39156334041323,
|
| 323 |
+
"accuracy": 0.5755178031184547,
|
| 324 |
+
"ece_15_bin": 0.011817411647322817
|
| 325 |
+
}
|
| 326 |
}
|
confusion_matrix.png
ADDED
|
eval_predictions.csv
ADDED
|
The diff for this file is too large to render.
See raw diff
|
|
|
evaluation.json
ADDED
|
@@ -0,0 +1,344 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
{
|
| 2 |
+
"schema": "gdc_yellowcab_public_evaluation_v1",
|
| 3 |
+
"checkpoint": {
|
| 4 |
+
"source_file_sha256": "0cb9c71d5be8f7671029e459c24179863ae2abff3ccfec1b5837c169d7d6c703",
|
| 5 |
+
"published_file": "model.safetensors",
|
| 6 |
+
"published_sha256": "af1a98cd96bb68d642f7a0adeedfacac37b230917afc15f3c87230a99a15b8a2",
|
| 7 |
+
"training_manifest_sha256": "8b92ad563892776cc25148f39fec6bf207e1e442c618b58fb07af7e2b899364d",
|
| 8 |
+
"split_sha256": "bfc5e960c8af32d0ea75a5e293bb95b3125111ace2cf8452eb42feb4bc2a1a5e"
|
| 9 |
+
},
|
| 10 |
+
"causal_input_audit": {
|
| 11 |
+
"policy": "When past-to-current displacement is below 4 m, encode unknown current heading as sin=0 and cos=1. No future bearing is used.",
|
| 12 |
+
"corrected_rows": 5974,
|
| 13 |
+
"total_rows": 74680,
|
| 14 |
+
"future_derived_model_inputs": 0
|
| 15 |
+
},
|
| 16 |
+
"protocol": {
|
| 17 |
+
"label_type": "GPS-derived silver maneuver proxy",
|
| 18 |
+
"forecast_horizon": "approximately 20 seconds",
|
| 19 |
+
"split_policy": "Complete forward-in-time route holdout; no frame from a validation or test route enters training.",
|
| 20 |
+
"dataset_samples": 74680,
|
| 21 |
+
"dataset_routes": 36,
|
| 22 |
+
"test_samples": 8594,
|
| 23 |
+
"test_routes": 5,
|
| 24 |
+
"training_seed": 20260726,
|
| 25 |
+
"route_bootstrap_iterations": 500
|
| 26 |
+
},
|
| 27 |
+
"primary_result": {
|
| 28 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 29 |
+
"samples": 8594,
|
| 30 |
+
"accuracy": 0.5755178031184547,
|
| 31 |
+
"balanced_accuracy": 0.39156334041323,
|
| 32 |
+
"macro_f1": 0.3915542657655546,
|
| 33 |
+
"weighted_f1": 0.5807008272180106,
|
| 34 |
+
"log_loss": 1.0841176199931875,
|
| 35 |
+
"brier_score": 0.5563128377237149,
|
| 36 |
+
"ece_15_bin": 0.011817411647322817,
|
| 37 |
+
"p95_latency_ms": 95.37229499110252,
|
| 38 |
+
"continue_recall": 0.7393577296489918,
|
| 39 |
+
"continue_f1": 0.7492904446546831,
|
| 40 |
+
"slow_recall": 0.35436382754994744,
|
| 41 |
+
"slow_f1": 0.37716843872411865,
|
| 42 |
+
"stop_recall": 0.3422712933753943,
|
| 43 |
+
"stop_f1": 0.3580858085808581,
|
| 44 |
+
"turn_left_recall": 0.3157262905162065,
|
| 45 |
+
"turn_left_f1": 0.27568134171907754,
|
| 46 |
+
"turn_right_recall": 0.20609756097560974,
|
| 47 |
+
"turn_right_f1": 0.19754529514903565,
|
| 48 |
+
"macro_f1_route_ci_low": 0.34762239048615595,
|
| 49 |
+
"macro_f1_route_ci_high": 0.42805096076291543
|
| 50 |
+
},
|
| 51 |
+
"baselines": [
|
| 52 |
+
{
|
| 53 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 54 |
+
"samples": 8594,
|
| 55 |
+
"accuracy": 0.5755178031184547,
|
| 56 |
+
"balanced_accuracy": 0.39156334041323,
|
| 57 |
+
"macro_f1": 0.3915542657655546,
|
| 58 |
+
"weighted_f1": 0.5807008272180106,
|
| 59 |
+
"log_loss": 1.0841176199931877,
|
| 60 |
+
"brier_score": 0.5563128377237149,
|
| 61 |
+
"ece_15_bin": 0.0118174116473228,
|
| 62 |
+
"p95_latency_ms": 95.37229499110252,
|
| 63 |
+
"continue_recall": 0.7393577296489918,
|
| 64 |
+
"continue_f1": 0.7492904446546831,
|
| 65 |
+
"slow_recall": 0.3543638275499474,
|
| 66 |
+
"slow_f1": 0.3771684387241186,
|
| 67 |
+
"stop_recall": 0.3422712933753943,
|
| 68 |
+
"stop_f1": 0.3580858085808581,
|
| 69 |
+
"turn_left_recall": 0.3157262905162065,
|
| 70 |
+
"turn_left_f1": 0.2756813417190775,
|
| 71 |
+
"turn_right_recall": 0.2060975609756097,
|
| 72 |
+
"turn_right_f1": 0.1975452951490356,
|
| 73 |
+
"macro_f1_route_ci_low": 0.3476223904861559,
|
| 74 |
+
"macro_f1_route_ci_high": 0.4280509607629154
|
| 75 |
+
},
|
| 76 |
+
{
|
| 77 |
+
"model": "Telemetry gradient boosting",
|
| 78 |
+
"samples": 8594,
|
| 79 |
+
"accuracy": 0.4147079357691413,
|
| 80 |
+
"balanced_accuracy": 0.4216633099655398,
|
| 81 |
+
"macro_f1": 0.341392924380058,
|
| 82 |
+
"weighted_f1": 0.4530356863806382,
|
| 83 |
+
"log_loss": 1.2490630281069546,
|
| 84 |
+
"brier_score": 0.6566714449096165,
|
| 85 |
+
"ece_15_bin": 0.1216700885218681,
|
| 86 |
+
"p95_latency_ms": NaN,
|
| 87 |
+
"continue_recall": 0.4051530993278566,
|
| 88 |
+
"continue_f1": 0.5513911828230212,
|
| 89 |
+
"slow_recall": 0.6466876971608833,
|
| 90 |
+
"slow_f1": 0.3416666666666667,
|
| 91 |
+
"stop_recall": 0.4889589905362776,
|
| 92 |
+
"stop_f1": 0.2986512524084778,
|
| 93 |
+
"turn_left_recall": 0.2797118847539016,
|
| 94 |
+
"turn_left_f1": 0.2583148558758315,
|
| 95 |
+
"turn_right_recall": 0.2878048780487804,
|
| 96 |
+
"turn_right_f1": 0.2569406641262928,
|
| 97 |
+
"macro_f1_route_ci_low": 0.3149153283503967,
|
| 98 |
+
"macro_f1_route_ci_high": 0.3493997015446531
|
| 99 |
+
},
|
| 100 |
+
{
|
| 101 |
+
"model": "Vision linear (efficientnet_b0)",
|
| 102 |
+
"samples": 8594,
|
| 103 |
+
"accuracy": 0.5751687223644403,
|
| 104 |
+
"balanced_accuracy": 0.2967510353079744,
|
| 105 |
+
"macro_f1": 0.305034605073554,
|
| 106 |
+
"weighted_f1": 0.5344562546214928,
|
| 107 |
+
"log_loss": 10.24602122531317,
|
| 108 |
+
"brier_score": 0.8349054717132016,
|
| 109 |
+
"ece_15_bin": 0.4091336187074714,
|
| 110 |
+
"p95_latency_ms": NaN,
|
| 111 |
+
"continue_recall": 0.8269230769230769,
|
| 112 |
+
"continue_f1": 0.7406354515050168,
|
| 113 |
+
"slow_recall": 0.1556256572029442,
|
| 114 |
+
"slow_f1": 0.2148040638606676,
|
| 115 |
+
"stop_recall": 0.252365930599369,
|
| 116 |
+
"stop_f1": 0.255591054313099,
|
| 117 |
+
"turn_left_recall": 0.1500600240096038,
|
| 118 |
+
"turn_left_f1": 0.1810282404055032,
|
| 119 |
+
"turn_right_recall": 0.098780487804878,
|
| 120 |
+
"turn_right_f1": 0.1331142152834839,
|
| 121 |
+
"macro_f1_route_ci_low": 0.2678056005630319,
|
| 122 |
+
"macro_f1_route_ci_high": 0.3273143437147999
|
| 123 |
+
},
|
| 124 |
+
{
|
| 125 |
+
"model": "Past-motion rule",
|
| 126 |
+
"samples": 8594,
|
| 127 |
+
"accuracy": 0.4549685827321387,
|
| 128 |
+
"balanced_accuracy": 0.223773826591683,
|
| 129 |
+
"macro_f1": 0.2235297785953733,
|
| 130 |
+
"weighted_f1": 0.4532542316647034,
|
| 131 |
+
"log_loss": 2.058490921490782,
|
| 132 |
+
"brier_score": 0.966304980218757,
|
| 133 |
+
"ece_15_bin": 0.4450314172678615,
|
| 134 |
+
"p95_latency_ms": NaN,
|
| 135 |
+
"continue_recall": 0.6562733383121733,
|
| 136 |
+
"continue_f1": 0.6534064504136072,
|
| 137 |
+
"slow_recall": 0.1019978969505783,
|
| 138 |
+
"slow_f1": 0.0962779156327543,
|
| 139 |
+
"stop_recall": 0.0,
|
| 140 |
+
"stop_f1": 0.0,
|
| 141 |
+
"turn_left_recall": 0.1776710684273709,
|
| 142 |
+
"turn_left_f1": 0.1792852816474863,
|
| 143 |
+
"turn_right_recall": 0.1829268292682926,
|
| 144 |
+
"turn_right_f1": 0.1886792452830188,
|
| 145 |
+
"macro_f1_route_ci_low": 0.1873463820585989,
|
| 146 |
+
"macro_f1_route_ci_high": 0.2345195759071031
|
| 147 |
+
},
|
| 148 |
+
{
|
| 149 |
+
"model": "Telemetry logistic",
|
| 150 |
+
"samples": 8594,
|
| 151 |
+
"accuracy": 0.196299744007447,
|
| 152 |
+
"balanced_accuracy": 0.2871892331606019,
|
| 153 |
+
"macro_f1": 0.1886698746182765,
|
| 154 |
+
"weighted_f1": 0.1861407158506876,
|
| 155 |
+
"log_loss": 1.5832758165931655,
|
| 156 |
+
"brier_score": 0.8215841116420504,
|
| 157 |
+
"ece_15_bin": 0.1432688177654283,
|
| 158 |
+
"p95_latency_ms": NaN,
|
| 159 |
+
"continue_recall": 0.109596713965646,
|
| 160 |
+
"continue_f1": 0.1816212871287128,
|
| 161 |
+
"slow_recall": 0.601472134595163,
|
| 162 |
+
"slow_f1": 0.2506024096385542,
|
| 163 |
+
"stop_recall": 0.3706624605678233,
|
| 164 |
+
"stop_f1": 0.1760959160734357,
|
| 165 |
+
"turn_left_recall": 0.1956782713085234,
|
| 166 |
+
"turn_left_f1": 0.1721224920802534,
|
| 167 |
+
"turn_right_recall": 0.1585365853658536,
|
| 168 |
+
"turn_right_f1": 0.162907268170426,
|
| 169 |
+
"macro_f1_route_ci_low": 0.1839562547318565,
|
| 170 |
+
"macro_f1_route_ci_high": 0.2044359347158287
|
| 171 |
+
},
|
| 172 |
+
{
|
| 173 |
+
"model": "Majority class",
|
| 174 |
+
"samples": 8594,
|
| 175 |
+
"accuracy": 0.6232255061670933,
|
| 176 |
+
"balanced_accuracy": 0.2,
|
| 177 |
+
"macro_f1": 0.1535770609318996,
|
| 178 |
+
"weighted_f1": 0.4785657076746885,
|
| 179 |
+
"log_loss": 1.1837257781136636,
|
| 180 |
+
"brier_score": 0.5768401032344809,
|
| 181 |
+
"ece_15_bin": 0.032749657591408,
|
| 182 |
+
"p95_latency_ms": NaN,
|
| 183 |
+
"continue_recall": 1.0,
|
| 184 |
+
"continue_f1": 0.7678853046594982,
|
| 185 |
+
"slow_recall": 0.0,
|
| 186 |
+
"slow_f1": 0.0,
|
| 187 |
+
"stop_recall": 0.0,
|
| 188 |
+
"stop_f1": 0.0,
|
| 189 |
+
"turn_left_recall": 0.0,
|
| 190 |
+
"turn_left_f1": 0.0,
|
| 191 |
+
"turn_right_recall": 0.0,
|
| 192 |
+
"turn_right_f1": 0.0,
|
| 193 |
+
"macro_f1_route_ci_low": 0.1460915032679738,
|
| 194 |
+
"macro_f1_route_ci_high": 0.1554760284937855
|
| 195 |
+
}
|
| 196 |
+
],
|
| 197 |
+
"per_class": [
|
| 198 |
+
{
|
| 199 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 200 |
+
"class": "continue",
|
| 201 |
+
"precision": 0.759493670886076,
|
| 202 |
+
"recall": 0.7393577296489918,
|
| 203 |
+
"f1": 0.7492904446546831,
|
| 204 |
+
"support": 5356
|
| 205 |
+
},
|
| 206 |
+
{
|
| 207 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 208 |
+
"class": "slow",
|
| 209 |
+
"precision": 0.40311004784689,
|
| 210 |
+
"recall": 0.3543638275499474,
|
| 211 |
+
"f1": 0.3771684387241186,
|
| 212 |
+
"support": 951
|
| 213 |
+
},
|
| 214 |
+
{
|
| 215 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 216 |
+
"class": "stop",
|
| 217 |
+
"precision": 0.3754325259515571,
|
| 218 |
+
"recall": 0.3422712933753943,
|
| 219 |
+
"f1": 0.3580858085808581,
|
| 220 |
+
"support": 634
|
| 221 |
+
},
|
| 222 |
+
{
|
| 223 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 224 |
+
"class": "turn_left",
|
| 225 |
+
"precision": 0.2446511627906976,
|
| 226 |
+
"recall": 0.3157262905162065,
|
| 227 |
+
"f1": 0.2756813417190775,
|
| 228 |
+
"support": 833
|
| 229 |
+
},
|
| 230 |
+
{
|
| 231 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 232 |
+
"class": "turn_right",
|
| 233 |
+
"precision": 0.1896745230078563,
|
| 234 |
+
"recall": 0.2060975609756097,
|
| 235 |
+
"f1": 0.1975452951490356,
|
| 236 |
+
"support": 820
|
| 237 |
+
}
|
| 238 |
+
],
|
| 239 |
+
"subsets": [
|
| 240 |
+
{
|
| 241 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 242 |
+
"subset": "all_test",
|
| 243 |
+
"samples": 8594,
|
| 244 |
+
"macro_f1": 0.3915542657655546,
|
| 245 |
+
"balanced_accuracy": 0.39156334041323,
|
| 246 |
+
"accuracy": 0.5755178031184547
|
| 247 |
+
},
|
| 248 |
+
{
|
| 249 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 250 |
+
"subset": "unseen_grid_cells",
|
| 251 |
+
"samples": 1846,
|
| 252 |
+
"macro_f1": 0.3342824235159851,
|
| 253 |
+
"balanced_accuracy": 0.3360174291252364,
|
| 254 |
+
"accuracy": 0.5384615384615384
|
| 255 |
+
},
|
| 256 |
+
{
|
| 257 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 258 |
+
"subset": "night_utc",
|
| 259 |
+
"samples": 6930,
|
| 260 |
+
"macro_f1": 0.4102137401798389,
|
| 261 |
+
"balanced_accuracy": 0.4080902962744183,
|
| 262 |
+
"accuracy": 0.5946608946608947
|
| 263 |
+
},
|
| 264 |
+
{
|
| 265 |
+
"model": "Temporal efficientnet_b0 + telemetry",
|
| 266 |
+
"subset": "gps_accuracy_le_10m",
|
| 267 |
+
"samples": 8319,
|
| 268 |
+
"macro_f1": 0.393316436996118,
|
| 269 |
+
"balanced_accuracy": 0.3936744515708604,
|
| 270 |
+
"accuracy": 0.5783147012862123
|
| 271 |
+
}
|
| 272 |
+
],
|
| 273 |
+
"selective_prediction": [
|
| 274 |
+
{
|
| 275 |
+
"confidence_threshold": 0.0,
|
| 276 |
+
"coverage": 1.0,
|
| 277 |
+
"accepted_examples": 8594,
|
| 278 |
+
"selective_accuracy": 0.5755178031184547,
|
| 279 |
+
"selective_macro_f1": 0.3915542657655546
|
| 280 |
+
},
|
| 281 |
+
{
|
| 282 |
+
"confidence_threshold": 0.25,
|
| 283 |
+
"coverage": 0.9987200372352804,
|
| 284 |
+
"accepted_examples": 8583,
|
| 285 |
+
"selective_accuracy": 0.5760223698007689,
|
| 286 |
+
"selective_macro_f1": 0.3919543899984051
|
| 287 |
+
},
|
| 288 |
+
{
|
| 289 |
+
"confidence_threshold": 0.35,
|
| 290 |
+
"coverage": 0.9100535257156156,
|
| 291 |
+
"accepted_examples": 7821,
|
| 292 |
+
"selective_accuracy": 0.6006904487917146,
|
| 293 |
+
"selective_macro_f1": 0.4060706565050537
|
| 294 |
+
},
|
| 295 |
+
{
|
| 296 |
+
"confidence_threshold": 0.45,
|
| 297 |
+
"coverage": 0.6947870607400511,
|
| 298 |
+
"accepted_examples": 5971,
|
| 299 |
+
"selective_accuracy": 0.658348685312343,
|
| 300 |
+
"selective_macro_f1": 0.4327252057994619
|
| 301 |
+
},
|
| 302 |
+
{
|
| 303 |
+
"confidence_threshold": 0.55,
|
| 304 |
+
"coverage": 0.4717244589248313,
|
| 305 |
+
"accepted_examples": 4054,
|
| 306 |
+
"selective_accuracy": 0.7323630981746423,
|
| 307 |
+
"selective_macro_f1": 0.470227025478709
|
| 308 |
+
},
|
| 309 |
+
{
|
| 310 |
+
"confidence_threshold": 0.65,
|
| 311 |
+
"coverage": 0.3019548522224808,
|
| 312 |
+
"accepted_examples": 2595,
|
| 313 |
+
"selective_accuracy": 0.8092485549132948,
|
| 314 |
+
"selective_macro_f1": 0.5275062675719726
|
| 315 |
+
},
|
| 316 |
+
{
|
| 317 |
+
"confidence_threshold": 0.75,
|
| 318 |
+
"coverage": 0.1748894577612287,
|
| 319 |
+
"accepted_examples": 1503,
|
| 320 |
+
"selective_accuracy": 0.8782435129740519,
|
| 321 |
+
"selective_macro_f1": 0.5566727737271018
|
| 322 |
+
},
|
| 323 |
+
{
|
| 324 |
+
"confidence_threshold": 0.85,
|
| 325 |
+
"coverage": 0.0829648592040958,
|
| 326 |
+
"accepted_examples": 713,
|
| 327 |
+
"selective_accuracy": 0.938288920056101,
|
| 328 |
+
"selective_macro_f1": 0.6097924940442192
|
| 329 |
+
}
|
| 330 |
+
],
|
| 331 |
+
"calibration": {
|
| 332 |
+
"method": "temperature scaling",
|
| 333 |
+
"temperature": 1.106177568435669,
|
| 334 |
+
"fit_split": "validation after restoring the best checkpoint",
|
| 335 |
+
"independent_calibration_split": false
|
| 336 |
+
},
|
| 337 |
+
"limitations": [
|
| 338 |
+
"Labels are GPS-derived proxies rather than human safety annotations.",
|
| 339 |
+
"The test set contains five held-out routes from one operating domain.",
|
| 340 |
+
"Raw accuracy is distorted by the majority continue class; macro F1 is primary.",
|
| 341 |
+
"The calibration set is the validation split, not an independent fourth split.",
|
| 342 |
+
"This evaluation is not evidence of safe vehicle control."
|
| 343 |
+
]
|
| 344 |
+
}
|
model.safetensors
CHANGED
|
@@ -1,3 +1,3 @@
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
-
oid sha256:
|
| 3 |
-
size
|
|
|
|
| 1 |
version https://git-lfs.github.com/spec/v1
|
| 2 |
+
oid sha256:af1a98cd96bb68d642f7a0adeedfacac37b230917afc15f3c87230a99a15b8a2
|
| 3 |
+
size 21384748
|
recompute_metrics.py
ADDED
|
@@ -0,0 +1,120 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
"""Recompute YellowCab's public held-out metrics from sanitized predictions."""
|
| 2 |
+
|
| 3 |
+
from __future__ import annotations
|
| 4 |
+
|
| 5 |
+
import json
|
| 6 |
+
from pathlib import Path
|
| 7 |
+
|
| 8 |
+
import numpy as np
|
| 9 |
+
import pandas as pd
|
| 10 |
+
from sklearn.metrics import (
|
| 11 |
+
accuracy_score,
|
| 12 |
+
balanced_accuracy_score,
|
| 13 |
+
brier_score_loss,
|
| 14 |
+
f1_score,
|
| 15 |
+
log_loss,
|
| 16 |
+
)
|
| 17 |
+
|
| 18 |
+
|
| 19 |
+
CLASSES = ("continue", "slow", "stop", "turn_left", "turn_right")
|
| 20 |
+
SEED = 20260726
|
| 21 |
+
BOOTSTRAP_ITERATIONS = 500
|
| 22 |
+
|
| 23 |
+
|
| 24 |
+
def expected_calibration_error(
|
| 25 |
+
probabilities: np.ndarray,
|
| 26 |
+
targets: np.ndarray,
|
| 27 |
+
*,
|
| 28 |
+
bins: int = 15,
|
| 29 |
+
) -> float:
|
| 30 |
+
confidence = probabilities.max(axis=1)
|
| 31 |
+
predictions = probabilities.argmax(axis=1)
|
| 32 |
+
correct = predictions == targets
|
| 33 |
+
edges = np.linspace(0.0, 1.0, bins + 1)
|
| 34 |
+
value = 0.0
|
| 35 |
+
for index in range(bins):
|
| 36 |
+
if index == bins - 1:
|
| 37 |
+
mask = (confidence >= edges[index]) & (confidence <= edges[index + 1])
|
| 38 |
+
else:
|
| 39 |
+
mask = (confidence >= edges[index]) & (confidence < edges[index + 1])
|
| 40 |
+
if mask.any():
|
| 41 |
+
value += float(mask.mean()) * abs(
|
| 42 |
+
float(correct[mask].mean()) - float(confidence[mask].mean())
|
| 43 |
+
)
|
| 44 |
+
return value
|
| 45 |
+
|
| 46 |
+
|
| 47 |
+
def route_bootstrap_macro_f1(
|
| 48 |
+
frame: pd.DataFrame,
|
| 49 |
+
targets: np.ndarray,
|
| 50 |
+
predictions: np.ndarray,
|
| 51 |
+
) -> tuple[float, float]:
|
| 52 |
+
route_values = frame["route_group"].astype(str).to_numpy()
|
| 53 |
+
routes = np.unique(route_values)
|
| 54 |
+
rng = np.random.default_rng(SEED)
|
| 55 |
+
values: list[float] = []
|
| 56 |
+
for _ in range(BOOTSTRAP_ITERATIONS):
|
| 57 |
+
sampled = rng.choice(routes, size=len(routes), replace=True)
|
| 58 |
+
indices = np.concatenate(
|
| 59 |
+
[np.flatnonzero(route_values == route) for route in sampled]
|
| 60 |
+
)
|
| 61 |
+
values.append(
|
| 62 |
+
float(
|
| 63 |
+
f1_score(
|
| 64 |
+
targets[indices],
|
| 65 |
+
predictions[indices],
|
| 66 |
+
labels=np.arange(len(CLASSES)),
|
| 67 |
+
average="macro",
|
| 68 |
+
zero_division=0,
|
| 69 |
+
)
|
| 70 |
+
)
|
| 71 |
+
)
|
| 72 |
+
return tuple(float(value) for value in np.quantile(values, [0.025, 0.975]))
|
| 73 |
+
|
| 74 |
+
|
| 75 |
+
def main() -> None:
|
| 76 |
+
root = Path(__file__).resolve().parent
|
| 77 |
+
frame = pd.read_csv(root / "eval_predictions.csv")
|
| 78 |
+
class_to_index = {name: index for index, name in enumerate(CLASSES)}
|
| 79 |
+
targets = frame["label"].map(class_to_index).to_numpy(dtype=np.int64)
|
| 80 |
+
predictions = frame["prediction"].map(class_to_index).to_numpy(dtype=np.int64)
|
| 81 |
+
probabilities = frame[
|
| 82 |
+
[f"prob_{class_name}" for class_name in CLASSES]
|
| 83 |
+
].to_numpy(dtype=np.float64)
|
| 84 |
+
if not np.allclose(probabilities.sum(axis=1), 1.0, atol=1e-6):
|
| 85 |
+
raise ValueError("Probability rows do not sum to one")
|
| 86 |
+
one_hot = np.eye(len(CLASSES), dtype=np.float64)[targets]
|
| 87 |
+
ci_low, ci_high = route_bootstrap_macro_f1(frame, targets, predictions)
|
| 88 |
+
result = {
|
| 89 |
+
"samples": int(len(frame)),
|
| 90 |
+
"routes": int(frame["route_group"].nunique()),
|
| 91 |
+
"accuracy": float(accuracy_score(targets, predictions)),
|
| 92 |
+
"balanced_accuracy": float(balanced_accuracy_score(targets, predictions)),
|
| 93 |
+
"macro_f1": float(
|
| 94 |
+
f1_score(
|
| 95 |
+
targets,
|
| 96 |
+
predictions,
|
| 97 |
+
labels=np.arange(len(CLASSES)),
|
| 98 |
+
average="macro",
|
| 99 |
+
zero_division=0,
|
| 100 |
+
)
|
| 101 |
+
),
|
| 102 |
+
"weighted_f1": float(
|
| 103 |
+
f1_score(
|
| 104 |
+
targets,
|
| 105 |
+
predictions,
|
| 106 |
+
labels=np.arange(len(CLASSES)),
|
| 107 |
+
average="weighted",
|
| 108 |
+
zero_division=0,
|
| 109 |
+
)
|
| 110 |
+
),
|
| 111 |
+
"log_loss": float(log_loss(targets, probabilities, labels=range(len(CLASSES)))),
|
| 112 |
+
"brier_score": float(np.mean(np.sum((probabilities - one_hot) ** 2, axis=1))),
|
| 113 |
+
"ece_15_bin": expected_calibration_error(probabilities, targets),
|
| 114 |
+
"macro_f1_route_ci_95": [ci_low, ci_high],
|
| 115 |
+
}
|
| 116 |
+
print(json.dumps(result, indent=2))
|
| 117 |
+
|
| 118 |
+
|
| 119 |
+
if __name__ == "__main__":
|
| 120 |
+
main()
|
selective_metrics.csv
ADDED
|
@@ -0,0 +1,9 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
confidence_threshold,coverage,accepted_examples,selective_accuracy,selective_macro_f1
|
| 2 |
+
0.0,1.0,8594,0.5755178031184547,0.3915542657655546
|
| 3 |
+
0.25,0.9987200372352805,8583,0.5760223698007689,0.3919543899984051
|
| 4 |
+
0.35,0.9100535257156156,7821,0.6006904487917146,0.4060706565050537
|
| 5 |
+
0.45,0.6947870607400511,5971,0.658348685312343,0.43272520579946194
|
| 6 |
+
0.55,0.4717244589248313,4054,0.7323630981746423,0.470227025478709
|
| 7 |
+
0.65,0.3019548522224808,2595,0.8092485549132948,0.5275062675719726
|
| 8 |
+
0.75,0.17488945776122877,1503,0.8782435129740519,0.5566727737271018
|
| 9 |
+
0.85,0.08296485920409588,713,0.938288920056101,0.6097924940442192
|
subset_metrics.csv
ADDED
|
@@ -0,0 +1,25 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
model,subset,samples,macro_f1,balanced_accuracy,accuracy
|
| 2 |
+
Majority class,all_test,8594,0.1535770609318996,0.2,0.6232255061670933
|
| 3 |
+
Majority class,unseen_grid_cells,1846,0.1571052631578947,0.2,0.6468039003250271
|
| 4 |
+
Majority class,night_utc,6930,0.1544077257021351,0.2,0.6287157287157287
|
| 5 |
+
Majority class,gps_accuracy_le_10m,8319,0.153802900266351,0.2,0.6247145089554033
|
| 6 |
+
Past-motion rule,all_test,8594,0.2235297785953733,0.223773826591683,0.4549685827321387
|
| 7 |
+
Past-motion rule,unseen_grid_cells,1846,0.2332335187587507,0.236197410832345,0.4842903575297941
|
| 8 |
+
Past-motion rule,night_utc,6930,0.2274748552099628,0.2276228825290112,0.4647907647907648
|
| 9 |
+
Past-motion rule,gps_accuracy_le_10m,8319,0.2233687790979745,0.2235505984136381,0.4570260848659694
|
| 10 |
+
Telemetry logistic,all_test,8594,0.1886698746182765,0.2871892331606019,0.196299744007447
|
| 11 |
+
Telemetry logistic,unseen_grid_cells,1846,0.1725156222420228,0.256991711558178,0.189599133261105
|
| 12 |
+
Telemetry logistic,night_utc,6930,0.1896834893067224,0.284189614812793,0.1988455988455988
|
| 13 |
+
Telemetry logistic,gps_accuracy_le_10m,8319,0.1864075839388003,0.2847033040497686,0.1962976319269143
|
| 14 |
+
Telemetry gradient boosting,all_test,8594,0.341392924380058,0.4216633099655398,0.4147079357691413
|
| 15 |
+
Telemetry gradient boosting,unseen_grid_cells,1846,0.3136214897768011,0.386078121522199,0.3959913326110509
|
| 16 |
+
Telemetry gradient boosting,night_utc,6930,0.3470049007798196,0.4262284930269192,0.4278499278499278
|
| 17 |
+
Telemetry gradient boosting,gps_accuracy_le_10m,8319,0.3426226516709886,0.4236167573460645,0.4168770284890011
|
| 18 |
+
Vision linear (efficientnet_b0),all_test,8594,0.305034605073554,0.2967510353079744,0.5751687223644403
|
| 19 |
+
Vision linear (efficientnet_b0),unseen_grid_cells,1846,0.2928477852235921,0.2881051221485449,0.5893824485373781
|
| 20 |
+
Vision linear (efficientnet_b0),night_utc,6930,0.3217391911486912,0.3126224230959082,0.5862914862914863
|
| 21 |
+
Vision linear (efficientnet_b0),gps_accuracy_le_10m,8319,0.3060672066310756,0.2972976109580328,0.576631806707537
|
| 22 |
+
Temporal efficientnet_b0 + telemetry,all_test,8594,0.3915542657655546,0.39156334041323,0.5755178031184547
|
| 23 |
+
Temporal efficientnet_b0 + telemetry,unseen_grid_cells,1846,0.3342824235159851,0.3360174291252364,0.5384615384615384
|
| 24 |
+
Temporal efficientnet_b0 + telemetry,night_utc,6930,0.4102137401798389,0.4080902962744183,0.5946608946608947
|
| 25 |
+
Temporal efficientnet_b0 + telemetry,gps_accuracy_le_10m,8319,0.393316436996118,0.3936744515708604,0.5783147012862123
|