

metadata
license: mit
pipeline_tag: robotics
tags:
  - autonomous-driving
  - imitation-learning
  - carla
  - transfuser
LEAD: Minimizing Learner–Expert Asymmetry in End-to-End Driving
Project Page | Paper | Code
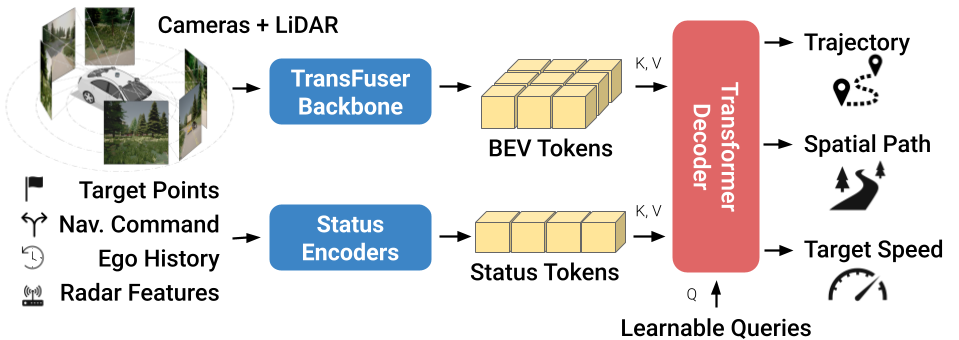
Official model weights for TransFuser v6 (TFv6), a set of CARLA driving policy checkpoints accompanies our paper LEAD: Minimizing Learner–Expert Asymmetry in End-to-End Driving.
We release the complete pipeline required to achieve state-of-the-art closed-loop performance on the Bench2Drive benchmark. Built around the CARLA simulator, the stack features a data-centric design with:
- Extensive visualization suite and runtime type validation for easier debugging.
- Optimized storage format, packs 72 hours of driving in ~200GB.
- Native support for NAVSIM and Waymo Vision-based E2E and extending those benchmarks through closed-loop simulation and synthetic data for additional supervision during training.
Find more information on https://github.com/autonomousvision/lead.
Usage
For setup instructions, data collection, and evaluation scripts, please refer to the official GitHub repository and the full documentation.
Citation
If you find this work useful, please cite:
@inproceedings{Nguyen2026CVPR,
    author = {Long Nguyen and Micha Fauth and Bernhard Jaeger and Daniel Dauner and Maximilian Igl and Andreas Geiger and Kashyap Chitta},
    title = {LEAD: Minimizing Learner-Expert Asymmetry in End-to-End Driving},
    booktitle = {Conference on Computer Vision and Pattern Recognition (CVPR)},
    year = {2026},
}
License
This project is released under the MIT License